零基础也能学!本课程教你用NVIDIA Isaac Sim在Ubuntu 24.04下免代码构建轮式机器人控制器,融合ROS2 Jazzy与Nav2导航栈,实现仿真到算法调试的完整闭环。
原始标题:NVIDIA Isaac Sim 101 – ROS2 & Robot Navigation
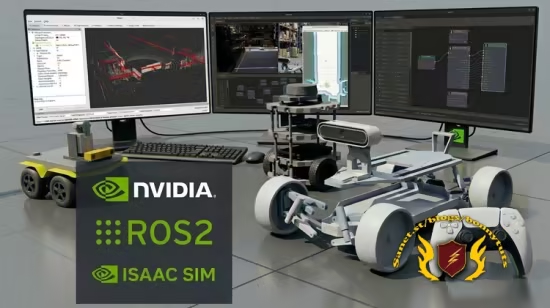
该课程是面向零编程基础学者的仿真先行(Simulation-First)移动机器人开发指南,核心在于让学员掌握在 Ubuntu 24.04 系统下,利用 NVIDIA Isaac Sim 进行高精度物理仿真的全流程。学员不仅能通过可视化图形编程工具 OmniGraph / ActionGraph 免代码构建包括差速、阿克曼和麦克纳姆轮在内的四种主流轮式底盘驱动控制器,还能在虚拟世界中部署、配置并输出相机、激光雷达(LiDAR)和惯导(IMU)等工业级传感器的数据流,打下扎实的机器人仿真基础。
在生态融合方面,课程重点聚焦于 NVIDIA Isaac Sim 与 ROS2 Jazzy 版本的深度桥接与协同演练。通过建立这一闭环系统,学员将学习如何把仿真环境中的传感器数据实时传输至 ROS2,驱动功能强大的 Nav2 导航堆栈进行建图、全自主路径规划与避障,并熟练运用 RViz 调试工具进行实时可视化。这套流程完美打通了“虚拟仿真到实际算法调试”的闭环,让没有任何底层开发经验的初学者也能自信地构建出达到工业级标准的自主机器人导航流水线。
Published 9/2026
Created by Simi Isaac
MP4 | Video: h264, 1920×1080 | Audio: AAC, 44.1 KHz, 2 Ch
Level: All Levels | Genre: eLearning | Language: English | Duration: 18 Lectures ( 2h 49m ) | Size: 2.9 GB
Wheeled Robot Control with ROS2 Jazzy, RViz, Nav2, OmniGraph and Isaac Sim.
What you’ll learn
⚡ Isaac Sim Basics
⚡ ROS2 with ActionGraph
⚡ Build Drive Controllers Using ActionGraph
⚡ Control Wheeled Mobile Robots in Simulation
⚡ Stream Sensor Data from Isaac Sim
⚡ Robot Navigation in Isaac Sim
Requirements
❗ No programming experience is needed. You will learn everything you need to know.
❗ Ubuntu 24
❗ Nvidia GPU min 8Gb VRAM
Description
Modern robotics is increasingly built around simulation-first development, and NVIDIA Isaac Sim is at the center of this shift. It allows us to design, test, and validate complex autonomous systems in a physically accurate virtual environment before deploying them to real hardware, saving time, cost, and reducing risk while accelerating development.
In this course, we will learn how to install and set up NVIDIA Isaac Sim and ROS2 from scratch, and understand the core concepts, interface, and workflow of Isaac Sim. We will build and connect robot logic using OmniGraph and create drive controllers for mobile robots using visual scripting. The course covers different wheeled robot systems, including differential drive (2-wheel and 4-wheel), Ackermann steering, and mecanum drive. We will also work with essential robotics sensors such as cameras, IMU, and LiDAR, and learn how to stream and process sensor data in simulation. In addition, you will integrate ROS2 with Isaac Sim to build real-world robotics workflows, robot navigation pipeline, and use mapping tools and RViz for visualization and debugging.
If you want to build real robotics skills with industry-grade simulation tools like NVIDIA Isaac Sim and ROS2, this course will give you the practical foundation to start developing autonomous systems confidently. Join now and see you in the course as we start building and experimenting together.
Who this course is for
⭐ Anyone who wants to build real-world robotics skills using NVIDIA Isaac Sim
百度网盘下载: